Robotics / Portfolio work
Multi-destination navigation for connected robots
A tool that connects mapping, path planning, and mission planning so robots can navigate to multiple destinations.
My role: Robotics tool developer
Project gallery
The challenge
A mission with several destinations requires a robot to connect individual paths across a shared map.
My approach
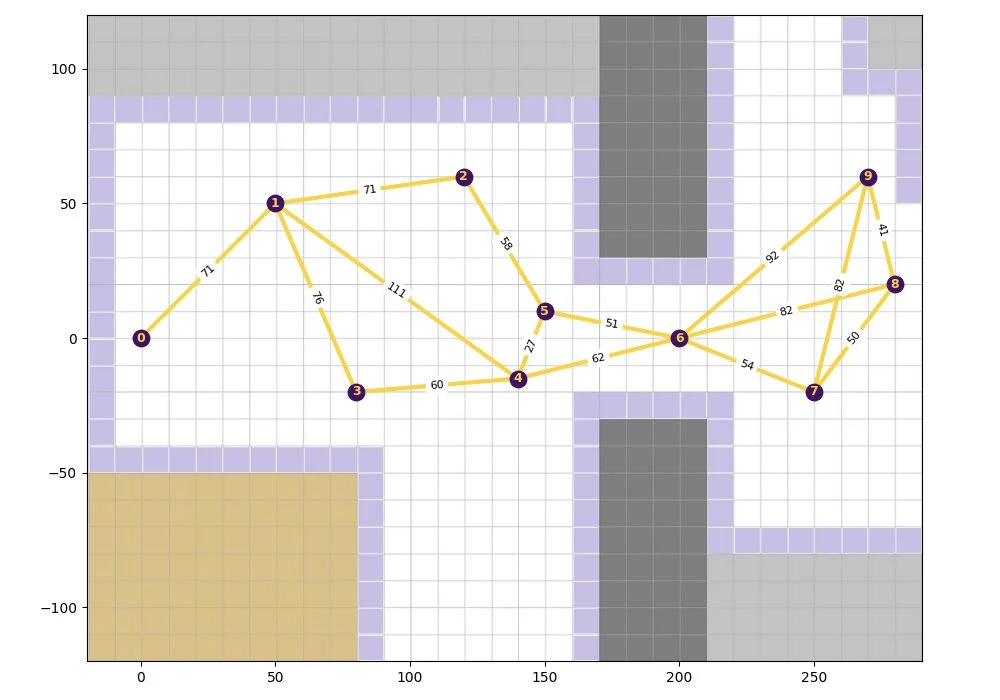
I developed modules for mapping the environment, planning paths, organizing missions, and navigating. The project image shows numbered waypoints and the connections available between them.
The result
The tool supports autonomous navigation with route optimization across multiple destinations.